Anurag Viswanadha Visagakoti

I build systems that perceive, reason and act. For most of my career that meant robots: SLAM for indoor drones at TCS Innovation Labs, visual servoing for space manipulators at IIIT Hyderabad, and neural 3D scene representations for navigation at Arizona State University.

Now I work on retrieval-augmented generation and multi-agent orchestration: systems that search a large pool of data and turn it into decisions someone can trust.

Full-length portrait of Anurag

Agents and retrieval

ZERO-EGRESS BOUNDARY no cloud LLM calls work items Azure DevOps prune Pydantic v2 ChromaDB RBAC ≤ L2 LANGGRAPH retrieve RAG context draft Llama 3 validate schema correct re-prompt retries < 3 report valid JSON
Figure 1. TFS Agent pipeline. Everything inside the dotted line runs on-prem.
Agents & RAG · Nirvana Health

TFS Agent

Sprint reports from Azure DevOps, written by agents that never send a byte off the network.

  1. 1Ingest. A two-stage client pulls work items and prunes them to typed summaries.
  2. 2Retrieve. ChromaDB search filters by the requester's clearance level inside the query.
  3. 3Draft and verify. Local Llama 3 drafts the report, and a LangGraph loop re-prompts until it passes the schema.
LangGraphLlama 3 · OllamaChromaDBFastAPIPydantic v2
PUSH-TO-TALK Cardputer · ESP32 ● LISTENING VOICE SERVER PCM STT Whisper agent loop LLM + tools memory · history TTS MP3 stream calendar time notes TOOLS pgvector spoken reply streams back to the device
Figure 2. Olexa voice loop, from button press to spoken answer.
Voice agent · Team project, co-builder

Olexa

Hold a button on a pocket-sized ESP32, ask a question, and hear the answer a moment later.

  1. 1Capture. The Cardputer streams 16 kHz push-to-talk audio over a WebSocket.
  2. 2Reason. The server transcribes it and runs a tool-using agent with memory.
  3. 3Respond. Text-to-speech streams the reply back to the device speaker.
TypeScriptWebSocketsESP32 · PlatformIOSupabase pgvectorBraintrust evals

Robotics and 3D vision

Robot path planned through a NeRF scene3D vision
ASU Active Perception Group

NeRF-based navigation

A navigation planner that plans directly in a neural radiance field of the scene.

NeRFPlanning
Gaussian splat reconstruction of a scene3D vision
ASU Active Perception Group

Gaussian splatting for SLAM

Bringing Gaussian splatting into the SLAM and 3D reconstruction pipeline.

3D GaussiansSLAM
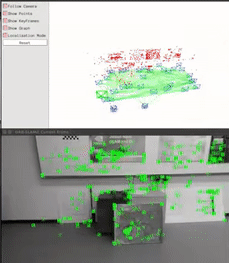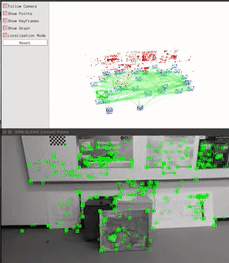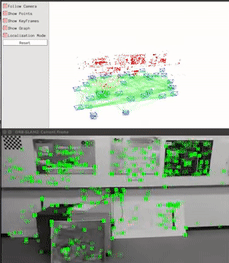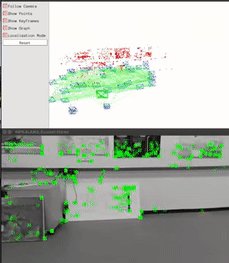
ORB-SLAM map built from a drone cameraSLAM
TCS Innovation Labs · 2017–2020

Dense mapping for drone navigation

ORB-SLAM dense mapping and localization from a drone-mounted RealSense camera for retail-space navigation.

ORB-SLAMROSRealSense
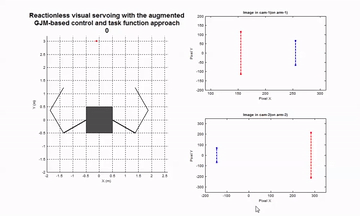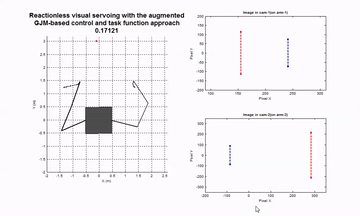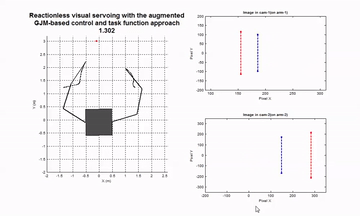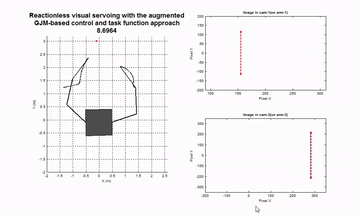
Dual-arm space robot simulationControl
IIIT Hyderabad · ICRA 2014

Reactionless visual servoing

Visual servoing for a dual-arm space robot that leaves the floating base undisturbed.

Visual servoingDynamics
RRT tree growing in image spacePlanning
IIIT Hyderabad · IROS 2016

Image-space path planning

RRT planning in image space for reactionless manipulation of a redundant space robot.

RRTSpace robotics

Experience

agents & AI robotics & 3D vision
  1. AI Engineer
    Nirvana Health
    Local-LLM agent and RAG pipelines over internal engineering data.
  2. 2026
    Co-builder
    Olexa
    Voice assistant: agent loop, streaming audio and ESP32 device client.
  3. 2022–2024
    M.S. Robotics & Autonomous Systems
    Arizona State University
    NeRF-based navigation and GNSS-aided LIO-SAM mapping. 4.0 GPA.
  4. 2022
    Director of Engineering
    Treadstone Media Labs
    Deep-learning tools for sketch-to-3D model generation, deployed in containers.
  5. 2017–2020
    Systems Engineer / Researcher
    TCS Innovation Labs
    Drone-based retail automation: SLAM, motion-capture calibration, ROS navigation.
  6. 2016
    Mechanical Design Engineer
    Asimov Robotics
    Led a team of six building a humanoid service robot with LiDAR navigation.
  7. 2016
    M.S. Computer Science
    IIIT Hyderabad
    Space-robot manipulation research at the Robotics Research Center.

Publications